17.10.2025
MCML at IROS 2025
Six Accepted Papers
IEEE/RSJ International Conference on Intelligent Robots and Systems, Hangzhou, China, Oct 19-25, 2025
We are happy to announce that MCML researchers have contributed a total of 6 papers to IROS 2025. Congrats to our researchers!
Main Track (6 papers)
Z. Chen • C. Li • X. Li • D. Huang • Z. Jiang • S. Speidel • X. Chu • K. W. S. Au
Vibration-Based Energy Metric for Restoring Needle Alignment in Autonomous Robotic Ultrasound.
IROS 2025 - IEEE/RSJ International Conference on Intelligent Robots and Systems. Hangzhou, China, Oct 19-25, 2025. DOI
Vibration-Based Energy Metric for Restoring Needle Alignment in Autonomous Robotic Ultrasound.
IROS 2025 - IEEE/RSJ International Conference on Intelligent Robots and Systems. Hangzhou, China, Oct 19-25, 2025. DOI
M.-A. Gafencu • R. Shaban • Y. Velikova • M. F. Azampour • N. Navab
Shape Completion and Real-Time Visualization in Robotic Ultrasound Spine Acquisitions.
IROS 2025 - IEEE/RSJ International Conference on Intelligent Robots and Systems. Hangzhou, China, Oct 19-25, 2025. DOI
Shape Completion and Real-Time Visualization in Robotic Ultrasound Spine Acquisitions.
IROS 2025 - IEEE/RSJ International Conference on Intelligent Robots and Systems. Hangzhou, China, Oct 19-25, 2025. DOI
S. B. Laina • S. Boche • S. Papatheodorou • D. Tzoumanikas • S. Schaefer • H. Chen • S. Leutenegger
Scalable Outdoors Autonomous Drone Flight with Visual-Inertial SLAM and Dense Submaps Built without LiDAR.
IROS 2025 - IEEE/RSJ International Conference on Intelligent Robots and Systems. Hangzhou, China, Oct 19-25, 2025. DOI GitHub
Scalable Outdoors Autonomous Drone Flight with Visual-Inertial SLAM and Dense Submaps Built without LiDAR.
IROS 2025 - IEEE/RSJ International Conference on Intelligent Robots and Systems. Hangzhou, China, Oct 19-25, 2025. DOI GitHub
M. de Mayo • D. Cremers • T. Pire
The Monado SLAM Dataset for Egocentric Visual-Inertial Tracking.
IROS 2025 - IEEE/RSJ International Conference on Intelligent Robots and Systems. Hangzhou, China, Oct 19-25, 2025. DOI
The Monado SLAM Dataset for Egocentric Visual-Inertial Tracking.
IROS 2025 - IEEE/RSJ International Conference on Intelligent Robots and Systems. Hangzhou, China, Oct 19-25, 2025. DOI
S. Wang • Q. Cheng • Q. Cheng • W. Zhang • S.-C. Wu • N. Zeller • D. Cremers • N. Navab
VoxNeRF: Bridging Voxel Representation and Neural Radiance Fields for Enhanced Indoor View Synthesis.
IROS 2025 - IEEE/RSJ International Conference on Intelligent Robots and Systems. Hangzhou, China, Oct 19-25, 2025. DOI
VoxNeRF: Bridging Voxel Representation and Neural Radiance Fields for Enhanced Indoor View Synthesis.
IROS 2025 - IEEE/RSJ International Conference on Intelligent Robots and Systems. Hangzhou, China, Oct 19-25, 2025. DOI
Y. Zhang • D. Huang • N. Navab • Z. Jiang
Tactile-Guided Robotic Ultrasound: Mapping Preplanned Scan Paths for Intercostal Imaging.
IROS 2025 - IEEE/RSJ International Conference on Intelligent Robots and Systems. Hangzhou, China, Oct 19-25, 2025. DOI
Tactile-Guided Robotic Ultrasound: Mapping Preplanned Scan Paths for Intercostal Imaging.
IROS 2025 - IEEE/RSJ International Conference on Intelligent Robots and Systems. Hangzhou, China, Oct 19-25, 2025. DOI
Related
29.10.2026
Teaching Language Models to Express Uncertainty
An ICLR 2026 paper shows how reinforcement learning improves confidence estimates from language models.
27.10.2026
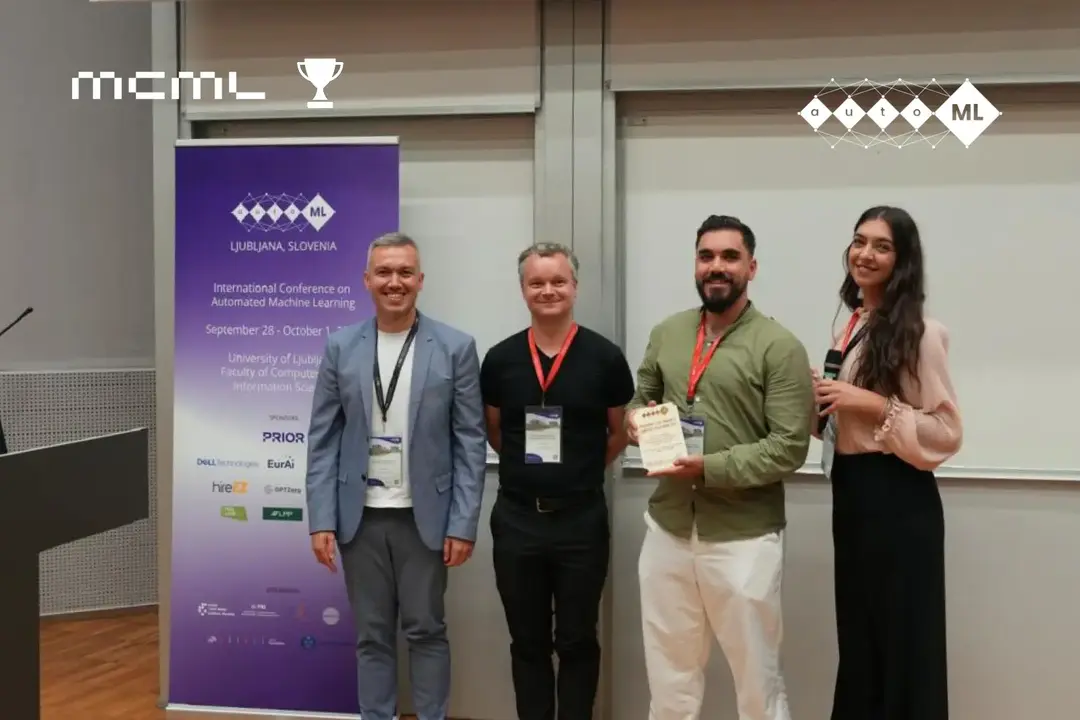
Runner-Up Prize at AutoML 2026 for Tabular-DC-Bench
Tabular-DC-Bench, by MCML Junior Member Mamdouh Aljoud and MCML Director Thomas Seidl, among others, won a runner-up prize at AutoML 2026.
27.10.2026
Welcoming Ewa Szczurek to MCML
Ewa Szczurek joins MCML as Professor of AI in Life Sciences at LMU, focusing on probabilistic and generative models for medicine.